Sprint acceleration mechanics and 4 proven rules that unlock explosive track speed
True athletic velocity is not decided at top speed, but in the violent initial meters where physics meets anatomy. Understanding how horizontal force projection governs the drive phase changes how athletes accelerate forever.
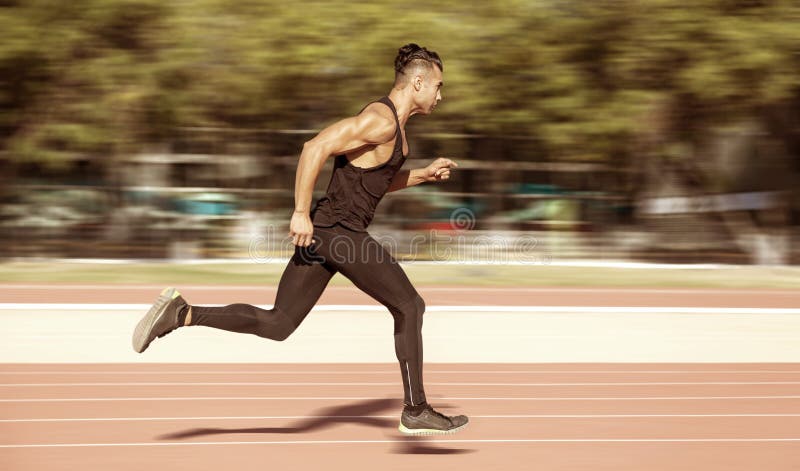
Mastering sprint acceleration mechanics separates runners who merely churn their legs from athletes who produce devastating horizontal velocity. When a sprinter leaves the starting blocks or breaks out of an athletic stance, raw effort alone cannot outrun the unforgiving laws of Newtonian physics. Acceleration is a violent negotiation between human muscular power and the solid track surface beneath it. Every millisecond of contact either propels the athlete forward or acts as an invisible brake, sabotaging potential speed before top gear is ever reached.
Most observers marvel at top-end velocity, watching athletes glide upright down the home stretch with apparent weightlessness. Yet human beings cannot hold top speed indefinitely, nor can they attain it without an uncompromising foundational launch. The outcome of any short-distance contest is largely sealed within the first twenty meters. By breaking down the mechanical architecture of the human drive phase, coaches and athletes can replace guesswork with clinical biomechanical precision.
The physics of horizontal force production against the track
Sprinting is an act of redirection. At the instant of departure, gravity anchors the body downward while the finish line beckons forward. The primary technical goal during the initial phase is the generation of massive relative ground reaction forces oriented horizontally rather than vertically. To accelerate an object, an external impulse must act upon its mass. The impulse-momentum theorem dictates that force multiplied by the duration of application equals the change in velocity. Because human foot contacts during early acceleration last merely 150 to 180 milliseconds, applying force rapidly in the correct orientation is the governing challenge.
Elite performers do not necessarily apply more total resultant force than their slower peers, but they possess a far superior vector index. They push backward against the ground with ruthless intentionality, ensuring the reaction force drives their center of mass forward along a low trajectory. Slower athletes waste substantial energy bouncing upward. Vertical force is indispensable later in the sprint when maintaining posture against gravity at maximal velocity, but premature vertical force during the start suffocates horizontal displacement. Understanding how sprint acceleration mechanics convert metabolic work into pure directional speed is what transforms raw strength into measurable ground performance.
Biomechanists measure this efficiency as the ratio of horizontal force to resultant ground reaction force. High-performing sprinters maintain a positive ratio across the first ten to fifteen strides. This requires an unyielding trunk, stable hip extension, and an ankle joint capable of locking into a rigid lever upon impact. If any anatomical link along that chain buckles under the load, energy bleeds into the joint structures instead of driving the track backward, destroying propulsion.
Why torso angle and shin angles dictate early velocity
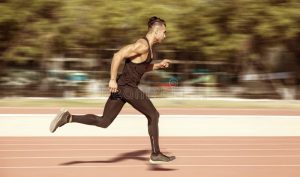
The visual hallmark of great acceleration is the forward lean. Yet amateur sprinters routinely misunderstand where that lean originates. Bending forward at the waist creates an optical illusion of acceleration while structurally ruining the body’s kinetic alignment. True acceleration lean is a unified straight line running from the ankle through the knee, hip, spine, and crown of the head. This unbroken diagonal posture aligns the musculoskeletal system directly with the ground reaction force vector.
A critical determinant of this alignment is the angle of the lower leg. Shin angles at ground contact dictate whether a step accelerates the athlete or halts their momentum. When the shin points backward or stands perpendicular to the running surface at initial contact, the foot lands in front of the center of mass. This creates an immediate braking force that jars the skeleton and halts acceleration dead in its tracks. Conversely, keeping a positive shin angle, where the knee leads the ankle forward, guarantees that foot strike occurs directly beneath or slightly behind the moving center of mass.
Maintaining these aggressive angles requires extraordinary eccentric and concentric strength through the posterior chain. Novice runners instinctively raise their chests because their stabilizing musculature cannot support the intense rotational torque demanded by low-angle propulsion. Yet a true grasp of sprint acceleration mechanics dismantles the widespread myth that sprinting is merely about moving feet as rapidly as possible. Stride frequency achieved by abandoning mechanical integrity yields nothing more than frantic, inefficient movement.
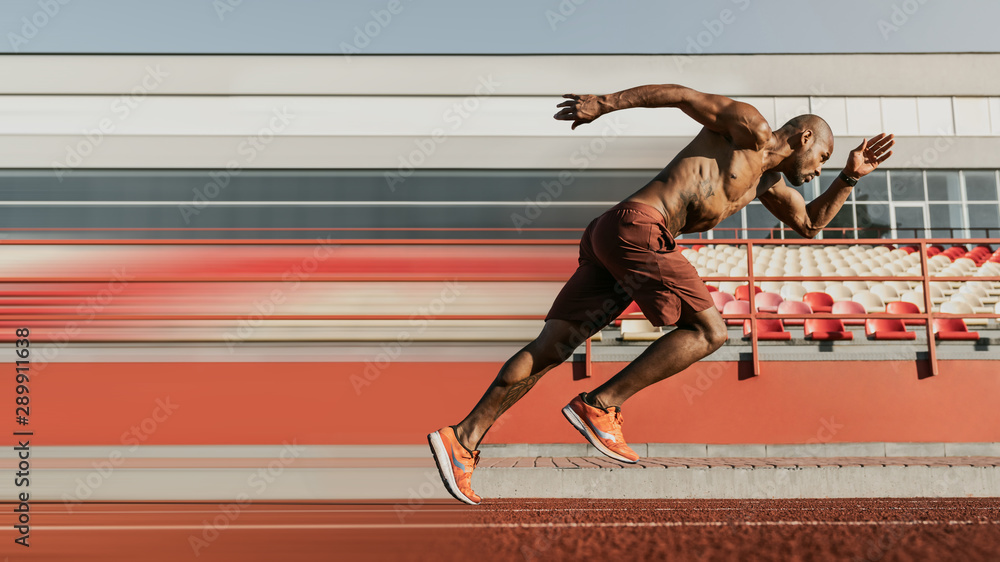
Four proven rules that optimize acceleration dynamics
When elite sprint coaches break down sprint acceleration mechanics into actionable components, four essential rules dictate success. These rules operate as an interconnected kinetic system where failure in one link invariably destabilizes the others.
Drive the ground backward instead of reaching forward
The human brain often equates running fast with reaching the front leg out to grab more territory. In acceleration, this intuition is completely wrong. Reaching forward forces the foot to touch the ground ahead of the pelvis, transforming the leg into an unintended pole vault that vaults the hips upward while braking horizontal speed. To eradicate this leak, the athlete must cultivate aggressive negative foot speed prior to touchdown.
Negative foot speed describes the active backward whip of the leg just before ground strike. Instead of passively dropping the foot, the hip extensors, primarily the gluteus maximus and hamstrings, fire furiously to accelerate the foot rearward. When the spikes touch the track, the foot is already traveling backward relative to the body at a speed matching or exceeding forward travel. This eliminates braking impulses and instantly transforms ground contact into an explosive, backward punch that drives the hips forward.
Maintain aggressive positive shin angles through early steps
The second rule governs the orientation of the tibia during the recovery and plant phases. Immediately after toe-off, the recovering foot should not cycle high toward the gluteus as it does in upright sprinting. High heel recovery takes valuable time and forces the knee into an elevated position that prematurely pulls the torso upright. During initial acceleration, the recovery foot must remain low, tracing a trajectory close to the ground in what track coaches call a low heel recovery.
This low trajectory allows the ankle and knee to shoot forward into an acute, positive angle. When the shin remains angled sharply toward the target, the foot strike can occur with a driving piston action rather than a circular clawing motion. Striking with positive shin angles ensures that each successive push acts along the same horizontal axis, compounding acceleration step over step like sequential charges in a combustion chamber.
Synchronize violent arm action to counterbalance rotational torque
Legs cannot operate at peak power in isolation. For every massive push the lower limbs exert into the earth, equal and opposite rotational forces travel upward into the pelvis and spine. Without balanced upper-body stabilization, the hips would twist erratically from side to side, leaking energy across the transverse plane. The arms act as the ultimate mechanical counterbalance.
During the drive phase, arm swings must be violent, long, and deliberate. The shoulder joint acts as the primary axis, with the hands driving from deep behind the hip to high past the chin. The backward drive of the elbow must match the explosive backward extension of the opposite hip. This dynamic pairing stabilizes the torso, anchors the rib cage, and prevents rotational drift. When executed correctly, aggressive arm action preserves the integrity of the kinetic chain, directing all generated force along the track line.
Control the rise through deliberate progressive upright transitions
The transition from a forty-five-degree drive posture to upright maximum velocity is not an abrupt pivot; it is a gradual, step-by-step unfolding that spans thirty to forty meters. Inexperienced sprinters frequently make the fatal mistake of popping their heads up after three or four strides. Popping up immediately switches the motor strategy from long-contact horizontal pushes to short-contact elastic vertical bounces, cutting acceleration short long before peak momentum is realized.
Athletes must visualize climbing an imaginary staircase, allowing each step to lift the torso by an imperceptible degree. The eyes stay focused on the track surface several meters ahead, avoiding the temptation to look at the finish line. Refining these sprint acceleration mechanics ensures that an athlete does not surrender acceleration distance, effectively stretching the speed-building window to its absolute physical maximum.
The neuromuscular reality of high rate of force development
The biomechanics of sprinting are underpinned by relentless neurological demands. An athlete may possess textbook kinematic angles, but without the physiological capacity to express massive force in fractional seconds, those angles collapse under real-world loads. Sprinting demands the highest rate of force development found anywhere in human athletics. Tendons and muscles must transition from rapid eccentric pre-loading to violent concentric output in under two-tenths of a second.
Data published across National Strength and Conditioning Association biomechanics reports consistently highlights that elite sprinters produce peak forces exceeding three to four times their body weight within the first 50 milliseconds of ground contact. This requires intense central nervous system output, recruiting high-threshold motor units composed of fast-twitch muscle fibers with millisecond synchronization.
Managing this intense physical demand requires structural balance and calculated force allocation. In other domains where rapid precision is vital, balancing system constraints determines the boundary between failure and success. Just as managing systemic risk in volatile trading environments relies on strict structural models like Option pricing mechanics and 4 proven rules that prevent devastating trading losses, maximizing athletic output requires biological precision to prevent soft-tissue avulsions while extracting maximum speed from the human chassis. The neurological underpinnings of sprint acceleration mechanics require the central nervous system to fire motor units with blistering synchrony, preventing the body from buckling against its own produced force.
Diagnosing common mechanical leaks on the track
Identifying mechanical breakdowns requires a sharp eye for kinematic subtleties. The most pervasive technical flaw in sprint acceleration is casting the foot. This occurs when an athlete anticipates the ground and straightens the knee prematurely before contact, reaching outward. The immediate result is an audible slap against the track, a sharp spike in braking forces, and enormous shear stress placed across the hamstring tendons. Overcoming this habit demands high volumes of wall march drills and heavy resisted sled sprints that force the leg to punch downward and backward under load.
Another common breakdown is lateral pelvic tilt, often resulting from weak gluteus medius musculature. As the stance foot takes the brunt of acceleration force, the opposite hip drops toward the track. This structural failure causes the torso to sway laterally, wasting energy across three planes instead of channeling it along one. Sprinters suffering from this issue often exhibit a weaving stride pattern instead of tracking along a crisp, straight corridor.
Heavy sled towing has emerged as one of the premier diagnostics and remedies for acceleration breakdowns. By loading a sled with thirty to fifty percent of the athlete’s body weight, the acceleration phase is artificially elongated. The increased resistance forces the athlete into positive shin angles and horizontal lean out of pure mechanical necessity. If the athlete attempts to pop upright or reach forward while towing heavy resistance, their momentum stalls instantly. The sled acts as an uncompromising coach, drilling proper vectors into the neuromuscular blueprint through repeated, high-load exposure.
The enduring pursuit of pure human velocity
Speed is not a mysterious gift bestowed exclusively upon the chosen few. While genetics dictate the ultimate ceiling of human capacity, proper mechanics dictate how close an athlete ever gets to that ceiling. Sprinting at its highest level is a display of engineering simplicity where the human anatomy acts as a living system of levers, pulleys, and springs.
When an athlete stops fighting the ground and begins manipulating force vectors with precision, the sensation of running changes completely. Frantic, high-effort thrashing gives way to rhythmic, explosive displacement. The initial steps cease to be a scramble for balance and become a sequence of powerful horizontal detonations. Ultimately, mastering sprint acceleration mechanics remains the ultimate testament to human locomotion stripped of excess and refined to pure directional intent.